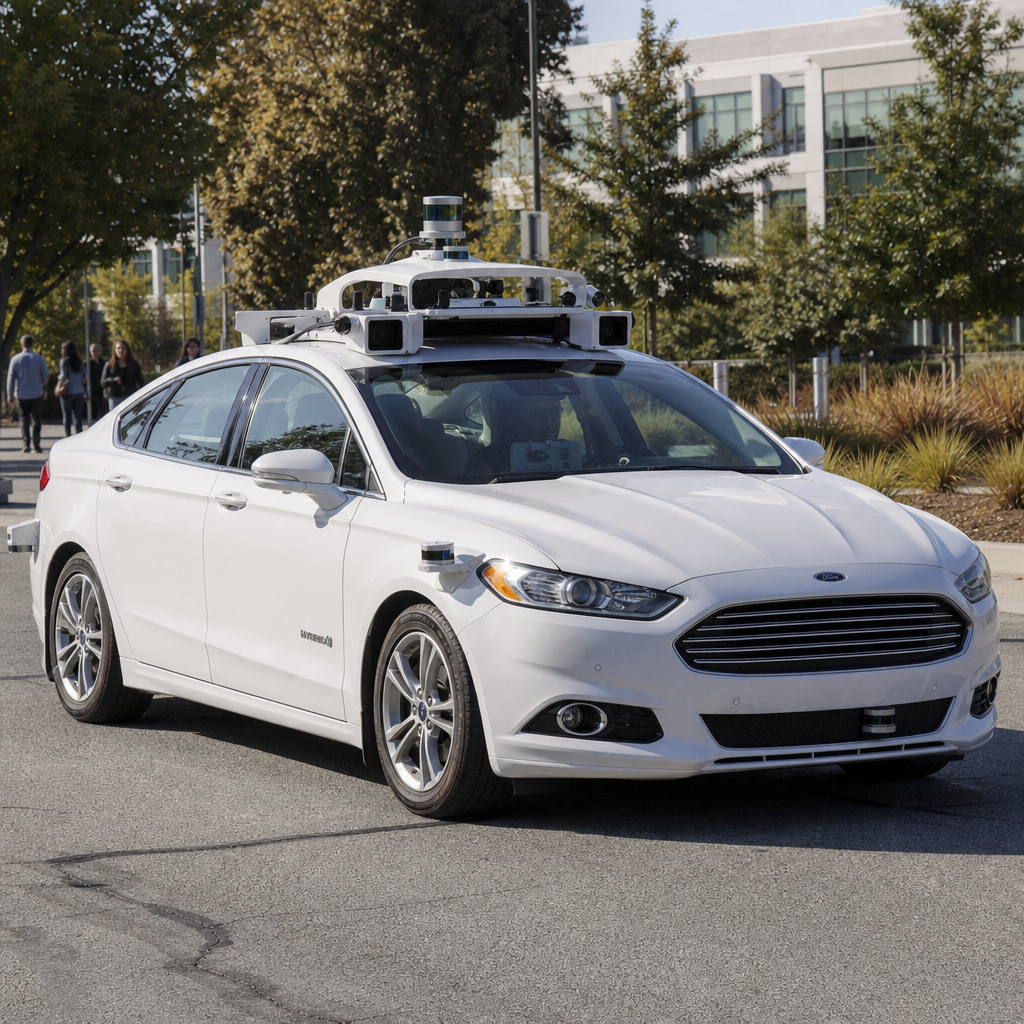
Silicon Valley’s role in advancing autonomous vehicle education is foundational because the region combines research universities, venture-backed startups, global technology firms, and test environments that turn theory into practical learning. Autonomous vehicle education refers to the structured process of teaching the software, hardware, safety, policy, and ethics behind self-driving systems. The learning curve in this field is steep: students must understand robotics, machine learning, sensor fusion, high-definition mapping, embedded systems, simulation, and transportation regulation. In my experience working with technical learning programs, no other ecosystem compresses those disciplines into such a visible, teachable pipeline as effectively as Silicon Valley. That matters because autonomous vehicles are not built by isolated coders or mechanical engineers alone; they emerge from interdisciplinary teams trained to handle uncertainty, edge cases, and safety-critical decisions.
For learners, educators, and employers, Silicon Valley functions as both a classroom and a proving ground. Stanford’s autonomous systems research, UC Berkeley’s transportation and AI work, NVIDIA’s computing platforms, and companies such as Waymo, Zoox, Aurora, and Nuro have shaped what students must know to be industry-ready. The region has also influenced curriculum design well beyond California. Courses now routinely include perception stacks, planning algorithms, human-machine interaction, and scenario-based validation because those skills are demanded by employers and regulators. As a hub within educational resources, this article maps the full learning curve: where beginners start, what intermediate learners build, how advanced training works, and why the Silicon Valley model continues to define autonomous vehicle education worldwide.
Why Silicon Valley Became the Center of Autonomous Vehicle Learning
Silicon Valley became central to autonomous vehicle education because it links talent, funding, infrastructure, and experimentation in one place. In practice, that means a learner can study computer vision in the morning, attend a robotics seminar in the afternoon, and review a company case study on real-world deployment by evening. Few regions offer that density. Stanford’s long influence on robotics and AI helped establish a research culture that values autonomous systems as applied science, not just academic theory. The DARPA Grand Challenge legacy also matters here. Many teams and leaders connected to that milestone later built programs, labs, and companies that directly shaped educational pathways.
The region also normalizes cross-functional training. A self-driving engineer cannot focus only on code if the vehicle must interpret lidar returns, predict pedestrian intent, and satisfy safety requirements under state rules. Silicon Valley companies train for that reality, and universities mirror it. Students learn ROS, Python, C++, CUDA-based acceleration, and simulation environments such as CARLA and LGSVL, but they also study system integration, failure analysis, and operational design domains. This combination reduces the gap between classroom work and production systems. That is why the learning curve here is demanding but unusually efficient.
What Beginners Need to Learn First
At the entry level, autonomous vehicle education should begin with the system architecture of a self-driving car. Beginners need a clear mental model of the stack: sensing, perception, localization, prediction, planning, control, and safety monitoring. Without that framework, technical details feel disconnected. I have found that students progress faster when they first understand how a camera frame becomes a lane estimate, how that estimate informs trajectory planning, and how control software converts a path into steering and braking commands. The goal at this stage is not mastery of every module but fluency in how the modules depend on one another.
Next come the foundational disciplines. Linear algebra, probability, calculus, and basic physics are essential because autonomous systems infer motion and uncertainty continuously. On the programming side, Python is useful for prototyping machine learning workflows, while C++ remains important for high-performance robotics code. Students should also learn data structures, Linux workflows, Git, and basic debugging. Sensor basics matter early as well. Cameras provide rich visual detail but struggle in some lighting conditions; radar is robust in poor weather and measures velocity well; lidar offers precise depth but adds cost and complexity. Understanding these tradeoffs is one of the first real steps in climbing the learning curve.
How Silicon Valley Institutions Shape the Curriculum
Silicon Valley’s educational influence is strongest in curriculum design. Universities and training providers increasingly organize autonomous vehicle courses around industry problems rather than isolated academic topics. Stanford and Berkeley have long integrated robotics, machine learning, optimization, and control theory into pathways that mirror autonomous vehicle workflows. A student might move from SLAM fundamentals to probabilistic state estimation, then into motion planning and simulation-based testing. That sequence reflects how real engineering teams build competence.
Industry participation deepens the curriculum. NVIDIA’s role in accelerated computing has made GPU programming and deep learning deployment more relevant in autonomous vehicle education. Open-source frameworks, public research papers, and conference talks from companies in the region expose students to practical issues like dataset bias, long-tail edge cases, and validation at scale. In workshops I have reviewed, the most effective lessons use real scenarios: an unprotected left turn, a cyclist emerging from occlusion, or a construction zone with degraded lane markings. These are not abstract examples. They represent the exact moments where perception, planning, and safety education must connect.
The Core Skills Behind the Learning Curve
The learning curve in autonomous vehicle education becomes steep when students move from concepts to implementation. They must combine software engineering discipline with robotics reasoning. A learner who can train an object detection model still needs to understand timestamp synchronization, sensor calibration, latency budgets, and real-time constraints. Perception accuracy alone does not produce safe autonomy. The vehicle must also localize reliably, predict other agents, and plan actions that remain stable under uncertainty.
| Skill Area | What Students Learn | Why It Matters in Practice |
|---|---|---|
| Perception | Object detection, segmentation, sensor fusion | Identifies lanes, vehicles, pedestrians, and obstacles |
| Localization | GNSS, IMU integration, SLAM, map matching | Keeps the vehicle aware of exact position |
| Prediction and Planning | Behavior forecasting, trajectory generation, decision logic | Determines safe responses to dynamic traffic |
| Control | PID, MPC, actuator commands, vehicle dynamics | Turns planned motion into steering, braking, and acceleration |
| Safety and Validation | Scenario testing, redundancy, disengagement review | Reduces risk in edge cases and system failures |
Strong programs in Silicon Valley teach these skills as an integrated stack. Students often start in simulation because it is safer and cheaper than road testing, then progress to recorded datasets and, eventually, supervised vehicle platforms. This staged approach is effective because it mirrors professional development pipelines. It also teaches an important truth: autonomy is not one algorithm but a system of systems.
Real-World Learning Through Labs, Startups, and Testbeds
One of Silicon Valley’s biggest educational advantages is access to real-world environments. Startups and established firms expose students and early-career engineers to iterative development cycles that textbooks cannot fully capture. In a lab, a model may score well on benchmark data. On a test route, the same model may fail when sun glare, road work, or unusual driver behavior alters the scene. Those lessons shape better engineers because they reveal the gap between academic performance and operational reliability.
Company ecosystems also teach students how autonomous vehicle teams actually work. Perception engineers coordinate with mapping teams, safety drivers, simulation specialists, and policy staff. Tools such as Apollo, Autoware, TensorRT, and distributed data pipelines show up in project-based learning because they reflect real workflows. Even when learners never touch a production fleet, exposure to those tools prepares them for the expectations of employers. Silicon Valley’s internship culture is especially important here. Interns often see annotation pipelines, dataset curation standards, incident review processes, and closed-course testing methods that are rarely covered deeply in general engineering programs.
Safety, Ethics, and Regulation as Essential Subjects
No serious autonomous vehicle education is complete without safety, ethics, and regulation. Silicon Valley has helped push this topic into the center of the curriculum because public trust is now as important as technical progress. Students must understand why a high-performing model is not automatically a safe deployable system. They need exposure to hazard analysis, redundancy design, fallback strategies, and safety case reasoning. Standards such as ISO 26262 and the Safety of the Intended Functionality framework are frequently referenced because they guide how engineers think about functional safety and performance limitations.
Ethics also belongs in the learning curve, but not as a vague classroom debate. It should be tied to concrete issues: training data bias, accessibility, interactions with pedestrians and cyclists, and the consequences of deployment in mixed-traffic environments. Regulatory literacy matters too. In California, testing and deployment rules shape how companies collect data, report incidents, and manage driverless operations. Learners who understand these constraints are more useful to employers and more realistic about the pace of adoption.
Building an Effective Educational Pathway
For most learners, the best pathway begins with fundamentals, moves into hands-on projects, and then specializes. Start with programming, math, and robotics basics. Add machine learning, sensor processing, and control systems. Then build projects: lane detection, path planning in simulation, sensor fusion with camera and radar, or localization using SLAM. After that, specialize in perception, planning, systems integration, or safety validation depending on career goals. This progression works because each stage reinforces the previous one.
Silicon Valley’s example shows that effective autonomous vehicle education is cumulative, collaborative, and grounded in reality. The region has raised the standard for what the learning curve should include: interdisciplinary fundamentals, tool fluency, simulation competence, safety awareness, and exposure to deployment constraints. For readers exploring educational resources, that is the main lesson. Do not study self-driving technology as a narrow coding topic. Treat it as a full-stack transportation discipline shaped by AI, robotics, law, and human behavior. Use this hub to guide your next step, then choose a subtopic and start building practical experience today.
Frequently Asked Questions
Why is Silicon Valley considered such an important hub for autonomous vehicle education?
Silicon Valley plays a uniquely important role in autonomous vehicle education because it brings together nearly every ingredient needed to train future experts in the field. Students and professionals are not learning in isolation. They are surrounded by leading research universities, high-growth startups, major technology companies, venture capital firms, public policy discussions, and real-world testing environments. That concentration creates an ecosystem where ideas move quickly from the classroom to the lab, then into prototypes, simulations, and road testing.
Autonomous vehicle education is inherently interdisciplinary. It requires knowledge of robotics, machine learning, computer vision, sensor fusion, embedded systems, mapping, safety engineering, human-machine interaction, ethics, and transportation policy. In Silicon Valley, these subjects are not treated as separate silos for long. Learners can see how they connect in actual development workflows. For example, a student studying perception algorithms can also be exposed to lidar integration, vehicle operating systems, safety validation, and the legal questions that arise when self-driving systems are deployed in public spaces.
Another reason the region matters is access. Silicon Valley offers proximity to engineers, founders, researchers, and investors who are actively shaping the future of mobility. That means students can attend technical talks, participate in internships, collaborate on research, and study real case examples from organizations building autonomous systems at scale. Instead of learning only from textbooks, they learn from current industry practice, including both breakthroughs and setbacks. This practical exposure makes education more realistic, more rigorous, and more aligned with how autonomous vehicle systems are actually designed and evaluated.
What subjects are most important in autonomous vehicle education, and how does Silicon Valley strengthen that learning?
The most important subjects in autonomous vehicle education span both technical and non-technical domains. On the technical side, learners need a strong foundation in robotics, machine learning, computer vision, control systems, sensor technologies, simulation, high-performance computing, and software engineering. They also need to understand how autonomous systems perceive their environment, make decisions, plan routes, and control a vehicle safely in changing conditions. Just as importantly, they must study system testing, validation, cybersecurity, reliability, and fail-safe design.
Beyond the technical core, serious autonomous vehicle education also includes safety regulation, public policy, ethics, and human factors. A self-driving car does not operate only as a piece of software. It interacts with pedestrians, passengers, road infrastructure, emergency responders, and legal frameworks. That means students must be trained to think about accountability, edge cases, data privacy, accessibility, and the social consequences of automation. In a mature educational setting, these topics are woven into the curriculum rather than treated as afterthoughts.
Silicon Valley strengthens this learning by making it easier to connect theory with application. The region’s universities and companies often work on exactly the same problems students are studying: perception accuracy, simulation quality, sensor cost, compute efficiency, safety metrics, and scalable deployment. This makes the educational experience more current and more grounded. Learners can engage with modern toolchains, real datasets, advanced research papers, and practical engineering challenges. In effect, Silicon Valley helps transform autonomous vehicle education from a purely academic discipline into a career-ready, problem-solving experience.
How do universities, startups, and major tech companies in Silicon Valley work together to advance autonomous vehicle education?
One of Silicon Valley’s greatest advantages is the way universities, startups, and large technology companies reinforce one another. Universities provide foundational research, theoretical depth, and formal instruction. Startups contribute speed, experimentation, and a willingness to tackle niche or emerging problems. Major technology firms bring scale, infrastructure, massive computing resources, and the operational discipline required to deploy advanced systems. When these three groups interact closely, education becomes richer and far more relevant.
For students, this collaboration shows up in several ways. Universities may partner with companies on research projects, guest lectures, lab funding, and internship pipelines. Startups often offer students opportunities to work on smaller teams where they can see the entire development process, from data collection and model training to testing and iteration. Large firms may provide cloud platforms, simulation tools, open-source frameworks, and access to seasoned engineers who understand production-grade autonomous systems. Together, these experiences help learners develop both academic rigor and practical judgment.
This collaborative environment also improves the pace and quality of knowledge transfer. Breakthroughs in machine learning, mapping, simulation, and safety analysis move quickly into educational programs because faculty, founders, and industry leaders are often in direct conversation. Students benefit by learning not only what is technically possible, but also what is commercially viable, socially responsible, and legally acceptable. That broad exposure is essential in autonomous vehicle education, where success depends on integrating research excellence with real-world execution.
What makes autonomous vehicle education especially challenging, and how does Silicon Valley help students overcome that steep learning curve?
Autonomous vehicle education is challenging because it sits at the intersection of many demanding disciplines, each of which is complex on its own. Students must learn how sensors such as cameras, radar, and lidar gather data; how machine learning models interpret that data; how planning systems make driving decisions; and how control systems execute those decisions safely. At the same time, they must understand software architecture, real-time processing, validation methods, and the unpredictable behavior of real traffic environments. Few fields require this much depth and breadth at once.
The steep learning curve becomes even more difficult because autonomous systems must perform reliably in edge cases. It is not enough for a system to work under ideal conditions. Students must be trained to think about unusual weather, sensor failures, confusing road markings, unexpected pedestrian behavior, and ethical tradeoffs in split-second decisions. They also need to appreciate why safety in autonomous driving is measured differently from performance in many other software fields. Precision, redundancy, verification, and accountability are central to the discipline.
Silicon Valley helps learners overcome these challenges by surrounding them with resources and examples that accelerate understanding. Students can access cutting-edge research, advanced labs, mentorship from experienced practitioners, and exposure to real engineering workflows. They can study simulation environments, analyze field-testing data, and learn from teams that are actively solving deployment problems. Just as important, the culture of iteration in Silicon Valley encourages experimentation without losing sight of safety and responsibility. That combination helps students move faster while developing the disciplined mindset autonomous vehicle work requires.
How is Silicon Valley likely to shape the future of autonomous vehicle education in the coming years?
Silicon Valley is likely to shape the future of autonomous vehicle education by pushing programs toward greater integration, realism, and specialization. As self-driving technologies mature, education will move beyond introductory robotics and machine learning into more advanced topics such as safety assurance frameworks, scalable simulation, multimodal sensor fusion, explainable AI, edge computing, and regulatory compliance. Silicon Valley is well positioned to influence this shift because it remains one of the few places where cutting-edge research and deployment-focused engineering happen side by side.
We are also likely to see more hands-on and industry-connected learning models. That may include project-based courses built around autonomous system stacks, partnerships that let students work with real-world datasets, and training that mirrors the lifecycle of an autonomous vehicle program from prototyping through validation. As the field grows, educational pathways may become more specialized as well, with distinct tracks for perception engineering, vehicle systems, AI safety, simulation, mobility policy, and autonomous fleet operations. Silicon Valley’s ecosystem makes it easier to support that kind of depth.
Perhaps most importantly, the region will continue to influence how autonomous vehicle education addresses responsibility. The future of the field will not be defined by technical capability alone. It will also be shaped by public trust, legal standards, ethical design, accessibility, and environmental impact. Silicon Valley’s ongoing debates around innovation, regulation, and societal consequences can help educational programs prepare learners for those realities. In that sense, its role is not just to produce better engineers, but to help develop well-rounded autonomous vehicle professionals who understand the broader implications of the systems they build.